1. Build the base
Assemble the base frame, wheel mounts, and drivetrain structure. Verify wheel rotation and frame alignment before moving forward.
Follow these steps in order. Use the sidebar to keep track of your current phase during assembly.
This page introduces the nine assembly stages. The detailed parts lists, photos, wiring diagrams, and checks are still being prepared, so use the instructions supplied for your robot when building it. The team can help confirm the right steps for your unit.
Disconnect power before working on wiring, and ask the team if a connection is unclear. Keep the robot supported during early tests and check how to stop your unit before powering it up.
Assemble the base frame, wheel mounts, and drivetrain structure. Verify wheel rotation and frame alignment before moving forward.
Install side walls, support brackets, and enclosure structure. Confirm all load-bearing hardware is secured.
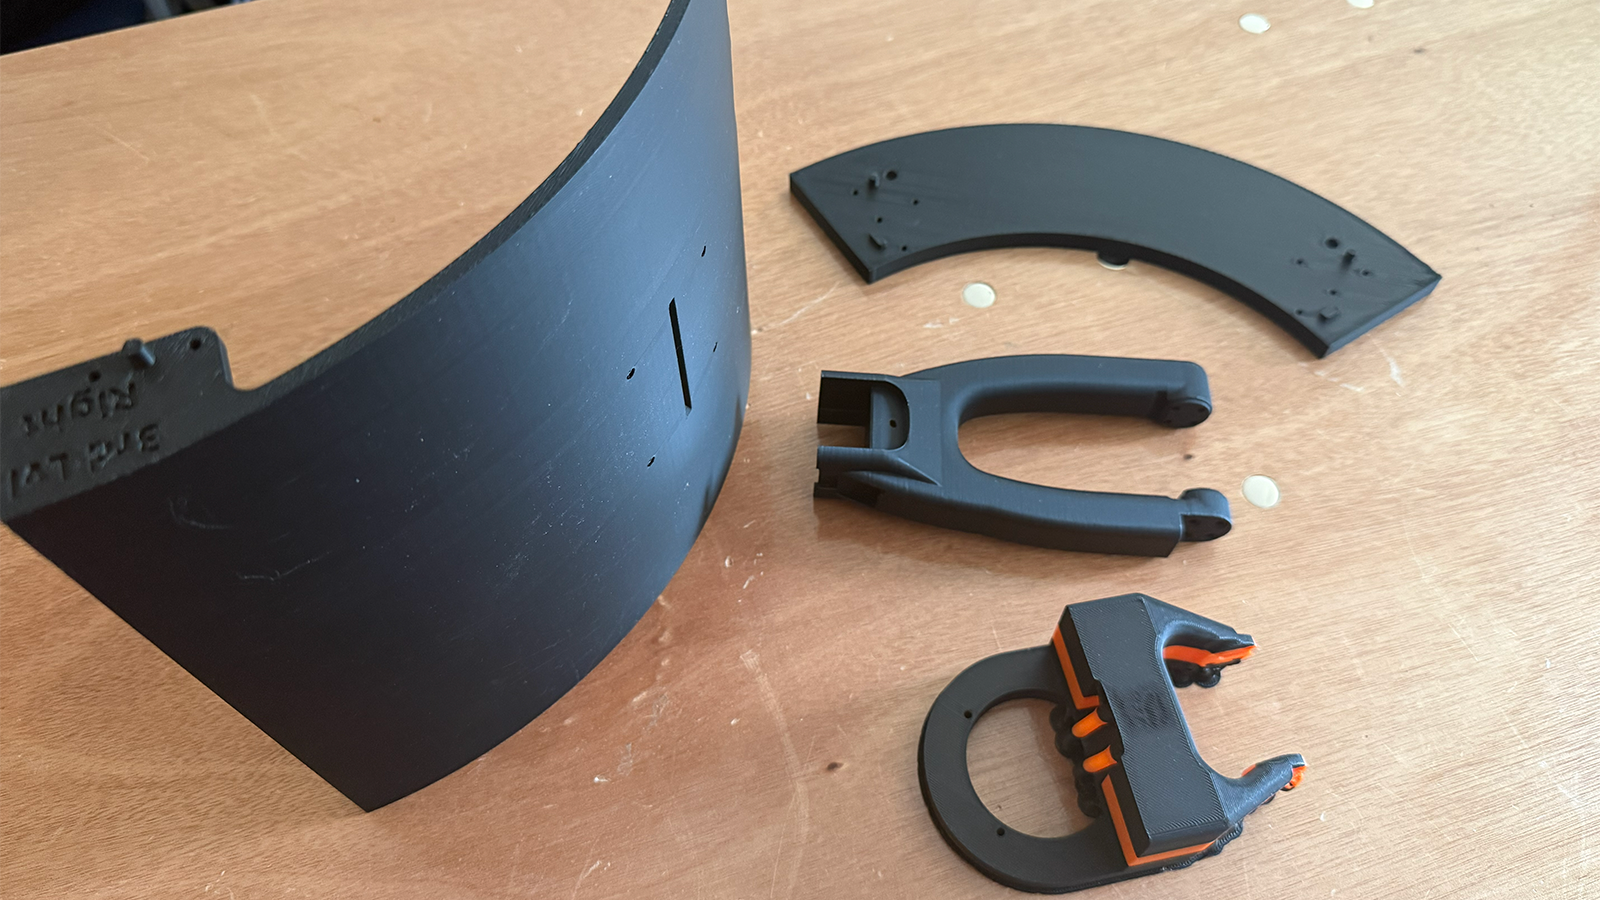
Wire power distribution, motor controllers, and sensor harnesses. Check polarity and add cable strain relief.
Flash the expected image, configure network access, and validate service startup from your desktop machine.
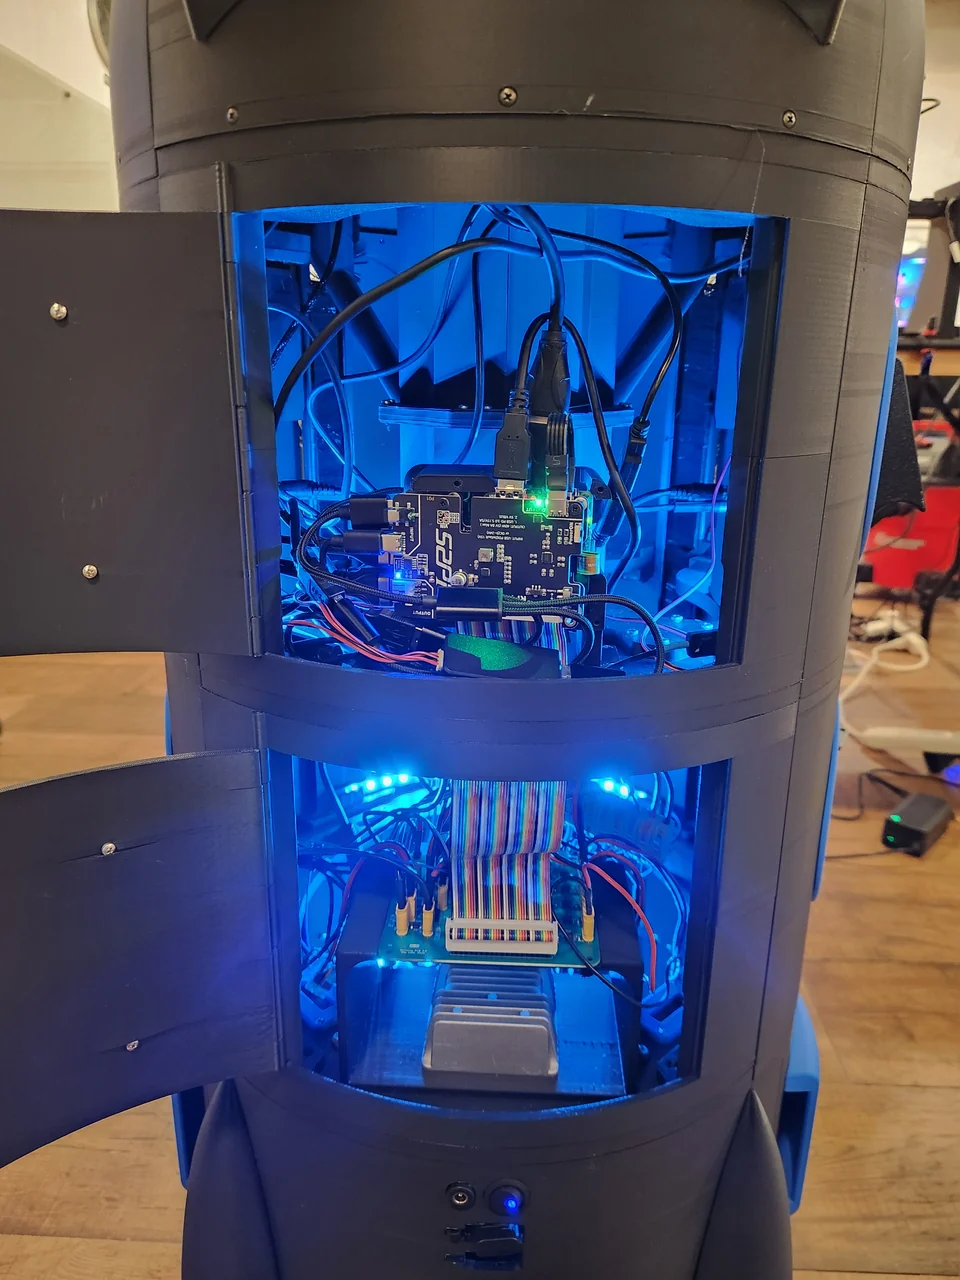
Assemble arm links and joints, verify mechanical travel limits, and confirm no collision across full range.
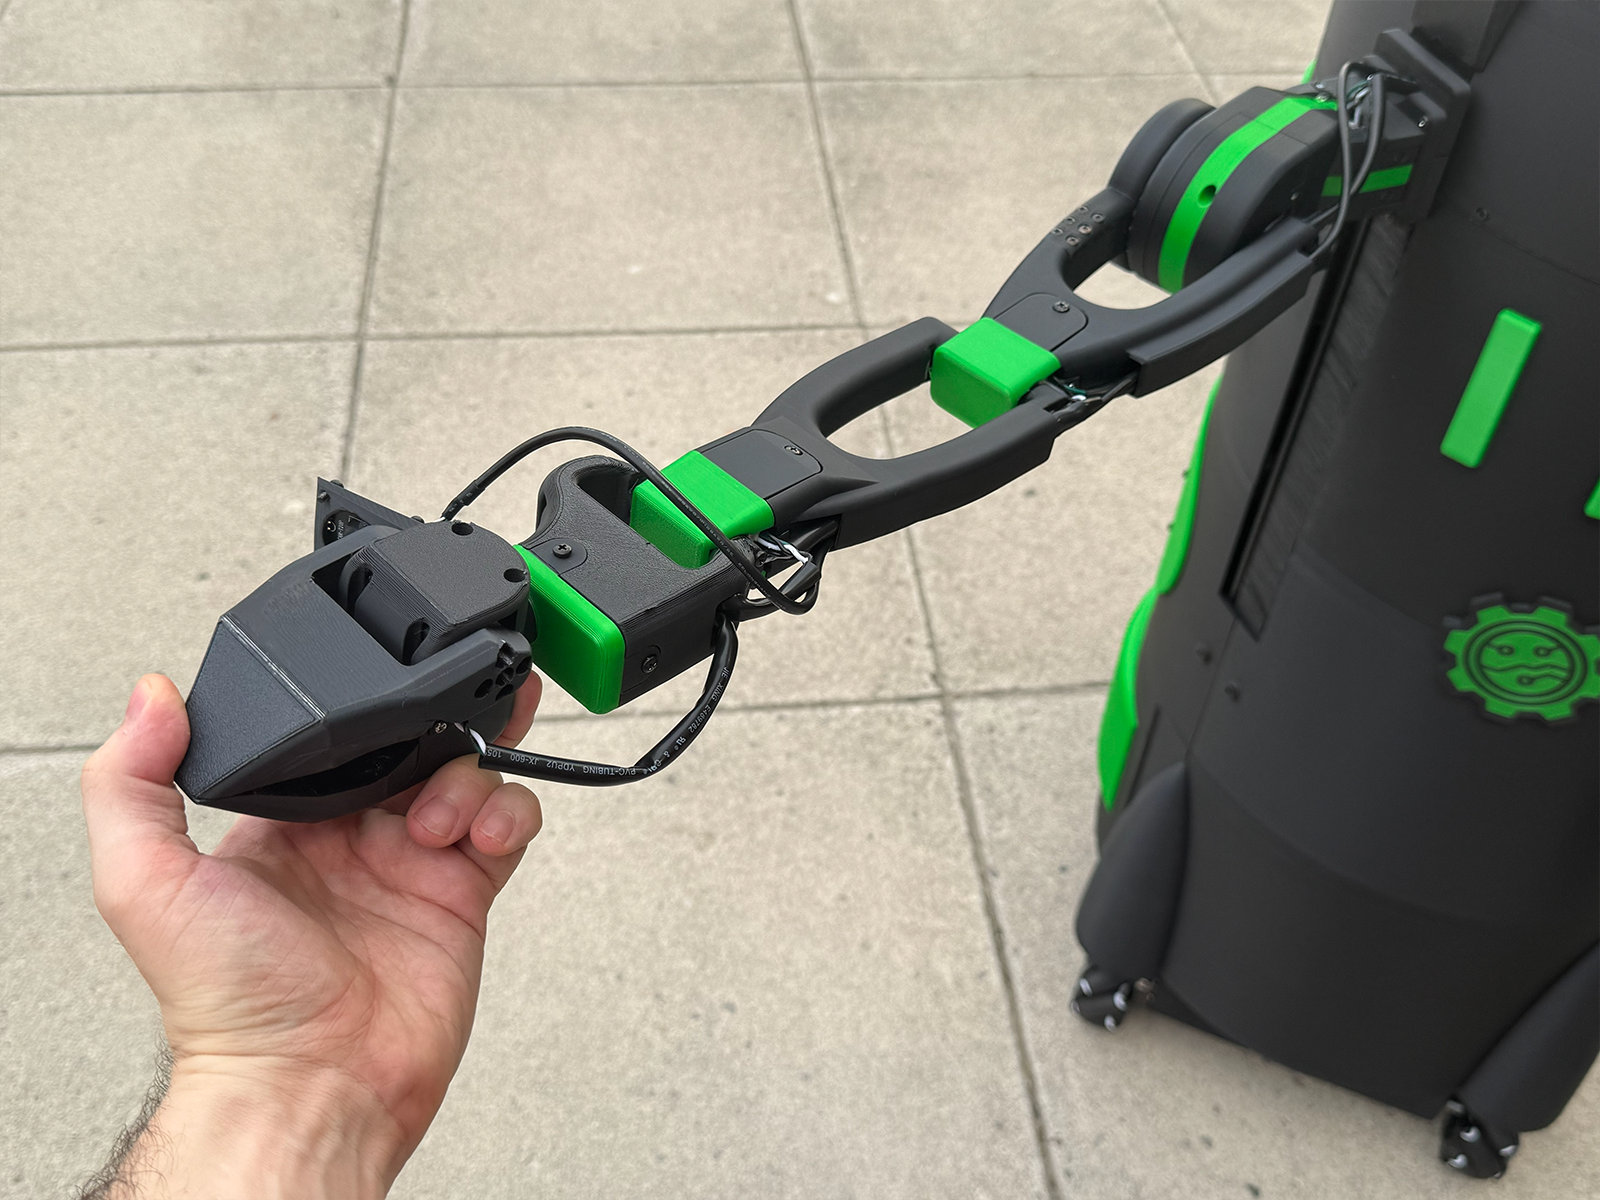
Build the dome enclosure and mount cameras/sensors. Confirm unobstructed sensor view and stable mounting.
Mount linear actuators, test extension/retraction direction, and verify controller channel mapping.
Connect potentiometer signals and calibrate minimum/maximum values so software readings match physical position.
Run final joint zeroing, wheel checks, and safety tests. Save calibration profiles before runtime software testing.