Teleoperate Sourccey
Verify the network, leader arms, robot, keyboard, and cameras together before collecting data.
Before you start
Check that this guide matches your robot and software. Before moving the robot, clear its workspace, stay nearby, and confirm the stopping procedure for your unit with the team. Stop controls and what happens when you release the controls can vary; closing a terminal does not replace a physical emergency stop.
- sourccey-host is running on the robot computer.
- The robot workspace is clear and the emergency stop is within reach.
- Both leader arms are connected and calibrated.
- You know the robot IP and both leader-arm ports.
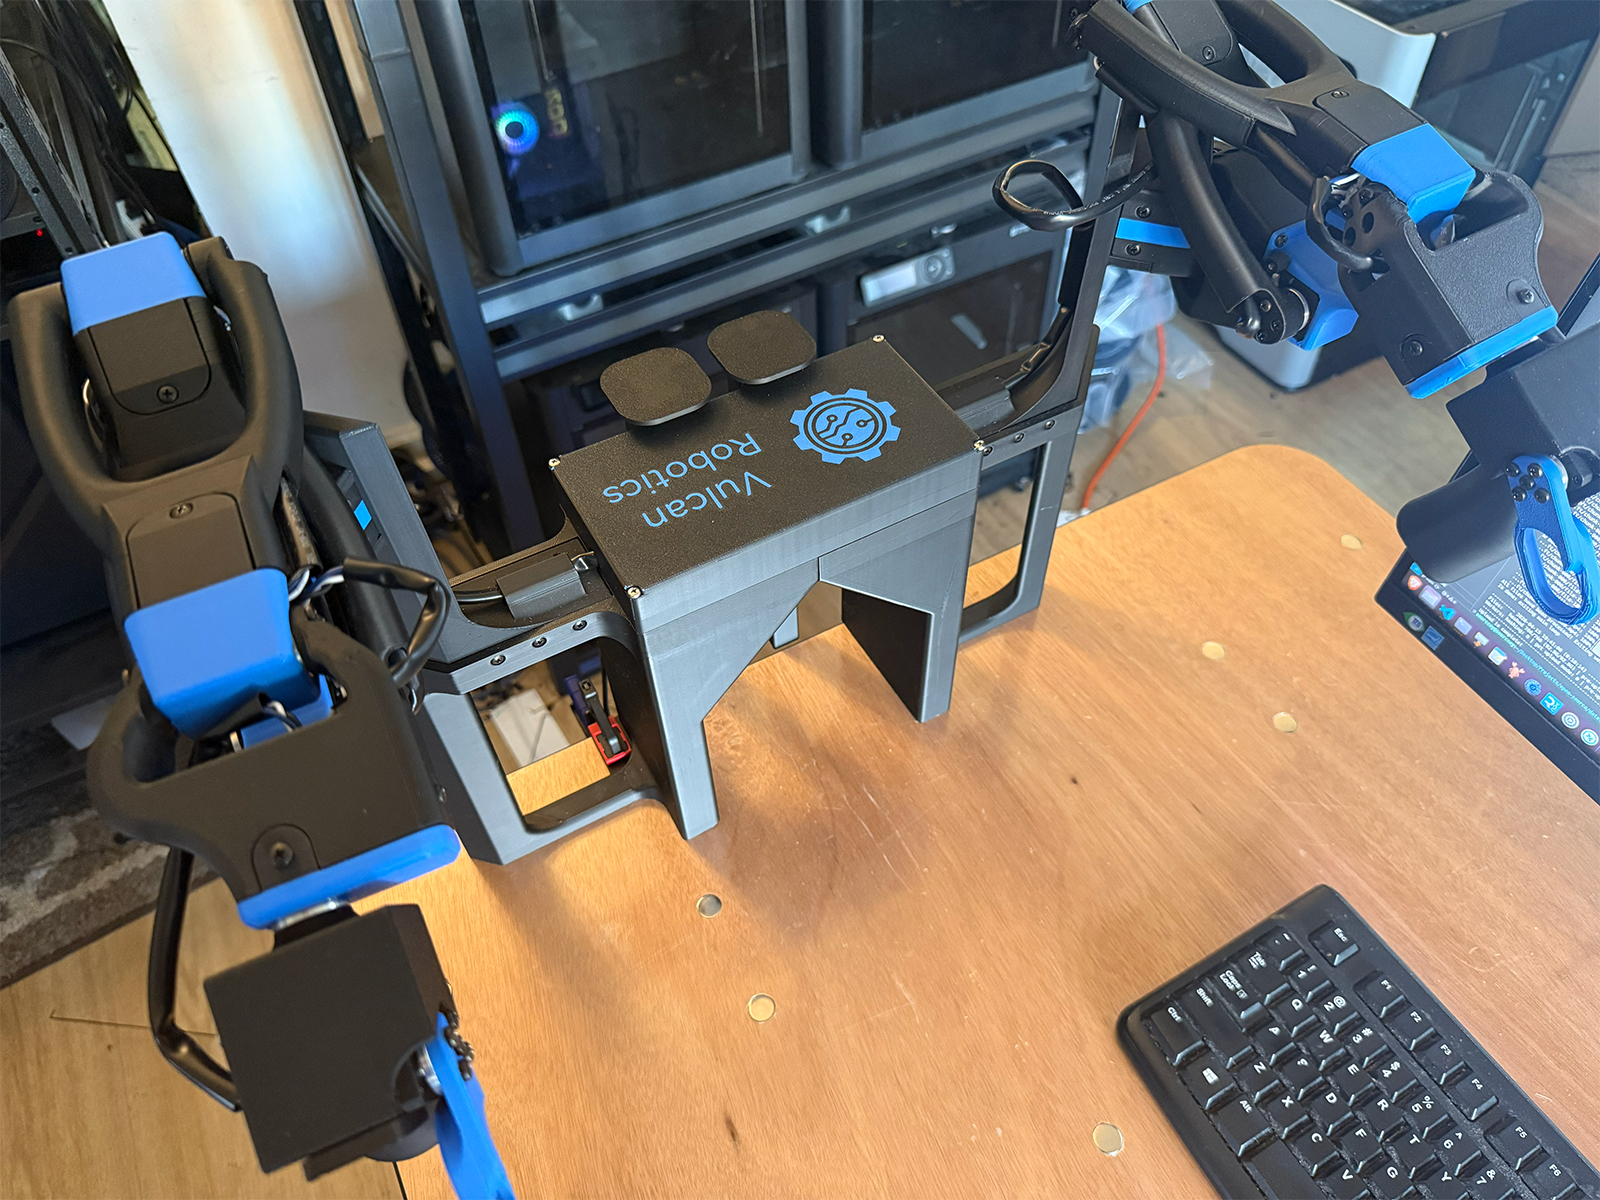
Run teleoperation
Run this on the controller computer. Replace the example IP address and COM ports first.
uv run lerobot-teleoperate --robot.type=sourccey_client --robot.id=sourccey --robot.remote_ip=192.168.1.243 --teleop.type=bi_sourccey_leader --teleop.id=sourccey_leader --teleop.left_arm_port=COM5 --teleop.right_arm_port=COM6 --teleop_keyboard.type=keyboard --teleop_keyboard.id=sourccey_keyboard --fps=30 --display_data=trueKeyboard controls
| Key | Action |
|---|---|
W / S | Move forward / backward |
A / D | Move left / right |
Z / X | Rotate left / right |
Q / E | Raise / lower the lift target |
R / F | Increase / decrease base speed |
N / M | Toggle left / right arm untorque |
Readiness check
- Each leader arm moves only its matching robot arm.
- Base and lift keys move in the expected direction.
- Camera images update in the display.
- Releasing the controls stops motion.
- The host shows no repeated timeout or device errors.
Stop teleoperation with Ctrl+C. Fix any failed check before recording.
About these examples: checks against a specific software version and a full hands-on walkthrough are still in progress. The source documentation below can help you and the team confirm the right instructions for your setup.
View upstream documentation·Read as Markdown